Research project · completed
HANSE

Overview
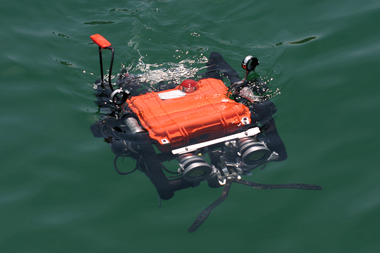
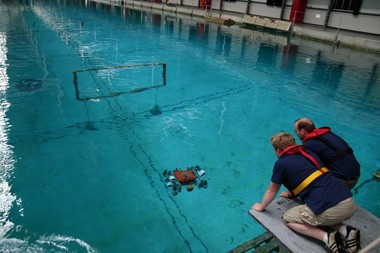
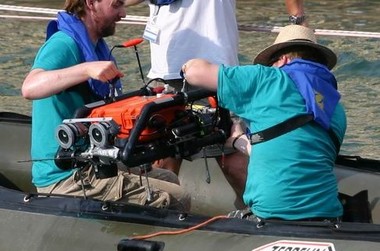
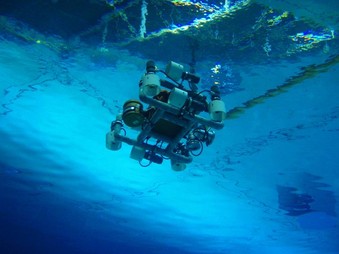
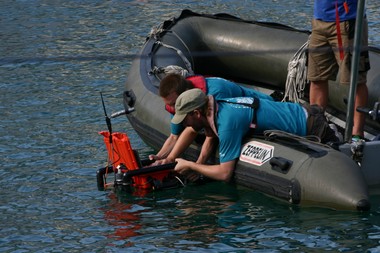
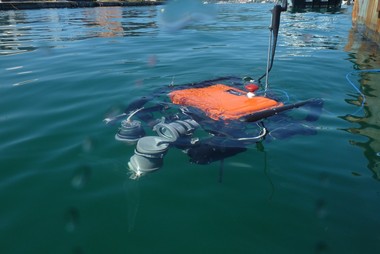
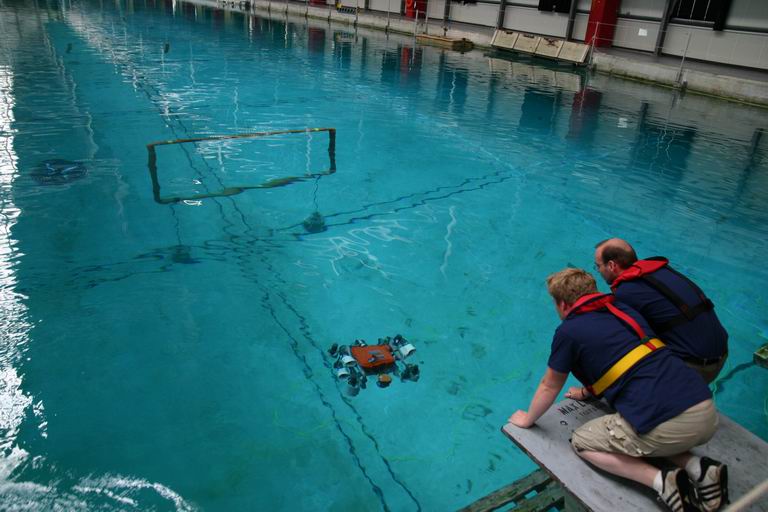
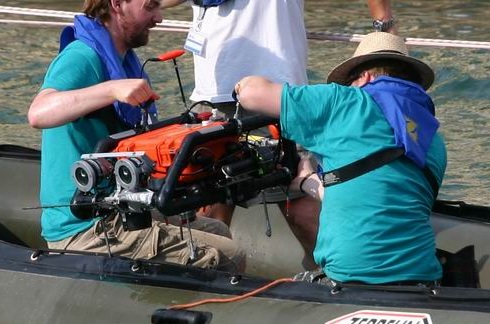
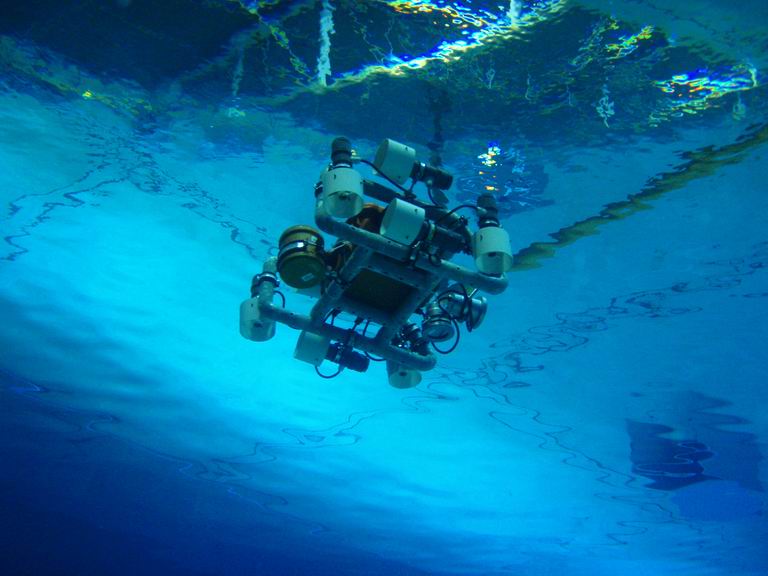
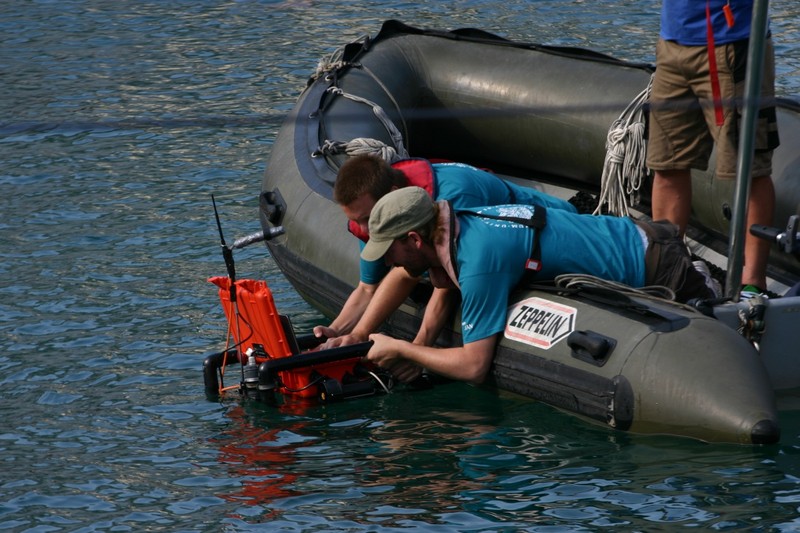
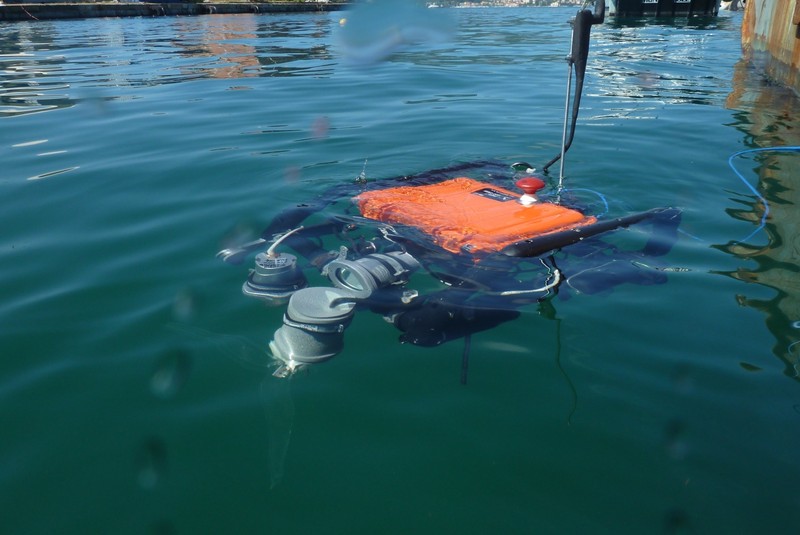
HANSE (Hanseatic Autonomous Nautic-Bot for SAUC-E) is an autonomous underwater vehicle (AUV) that was build for the Student Autonomous Underwater Challenge - Europe (SAUC-E). In his first attendance at the SAUC-E 2009 HANSE won the innovation award. At the SAUC-E 2011 HANSE won the first prize. In the SAUC-E 2012 we hold our ground on the second place.
Hardware
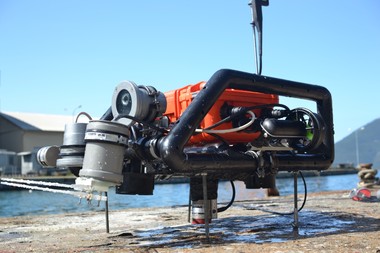
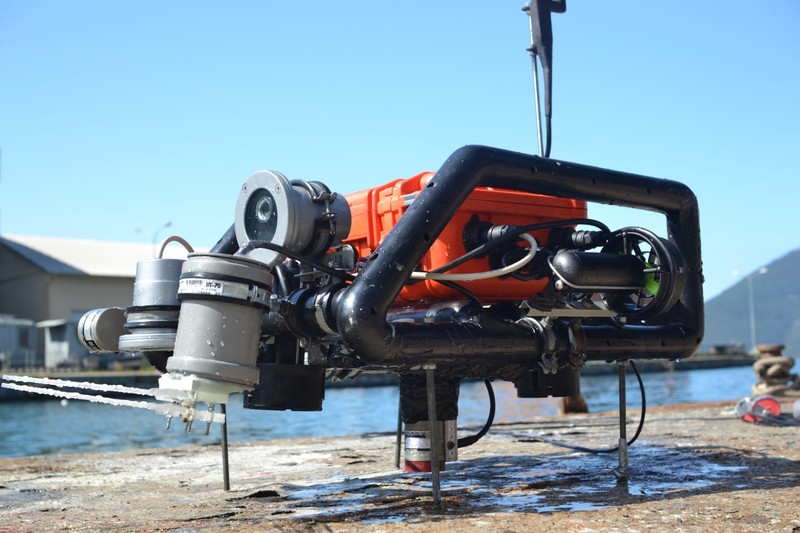
HANSE consists of a water-proof case in which a laptop resides. The case is mounted on a sledge so that we are very flexible in case of hardware extensions and switching like cameras. 4 Thrusters are responsible for propulsion. One scanning and echo sonar allows us to see our environment even in bad weather conditions. A INS-System gives us our orientation. The pressure sensor provides us with depth information.
Software
The software of HANSE changed significantly over the time. Currently a shift occurs from an own Qt-based framework to the robotic framework (ROS). With a common ground we hope to exchange code easily between all our projects.
Supported by: