Research project · completed
R3-COP
Resilient Reasoning Robotic Co-operating Systems
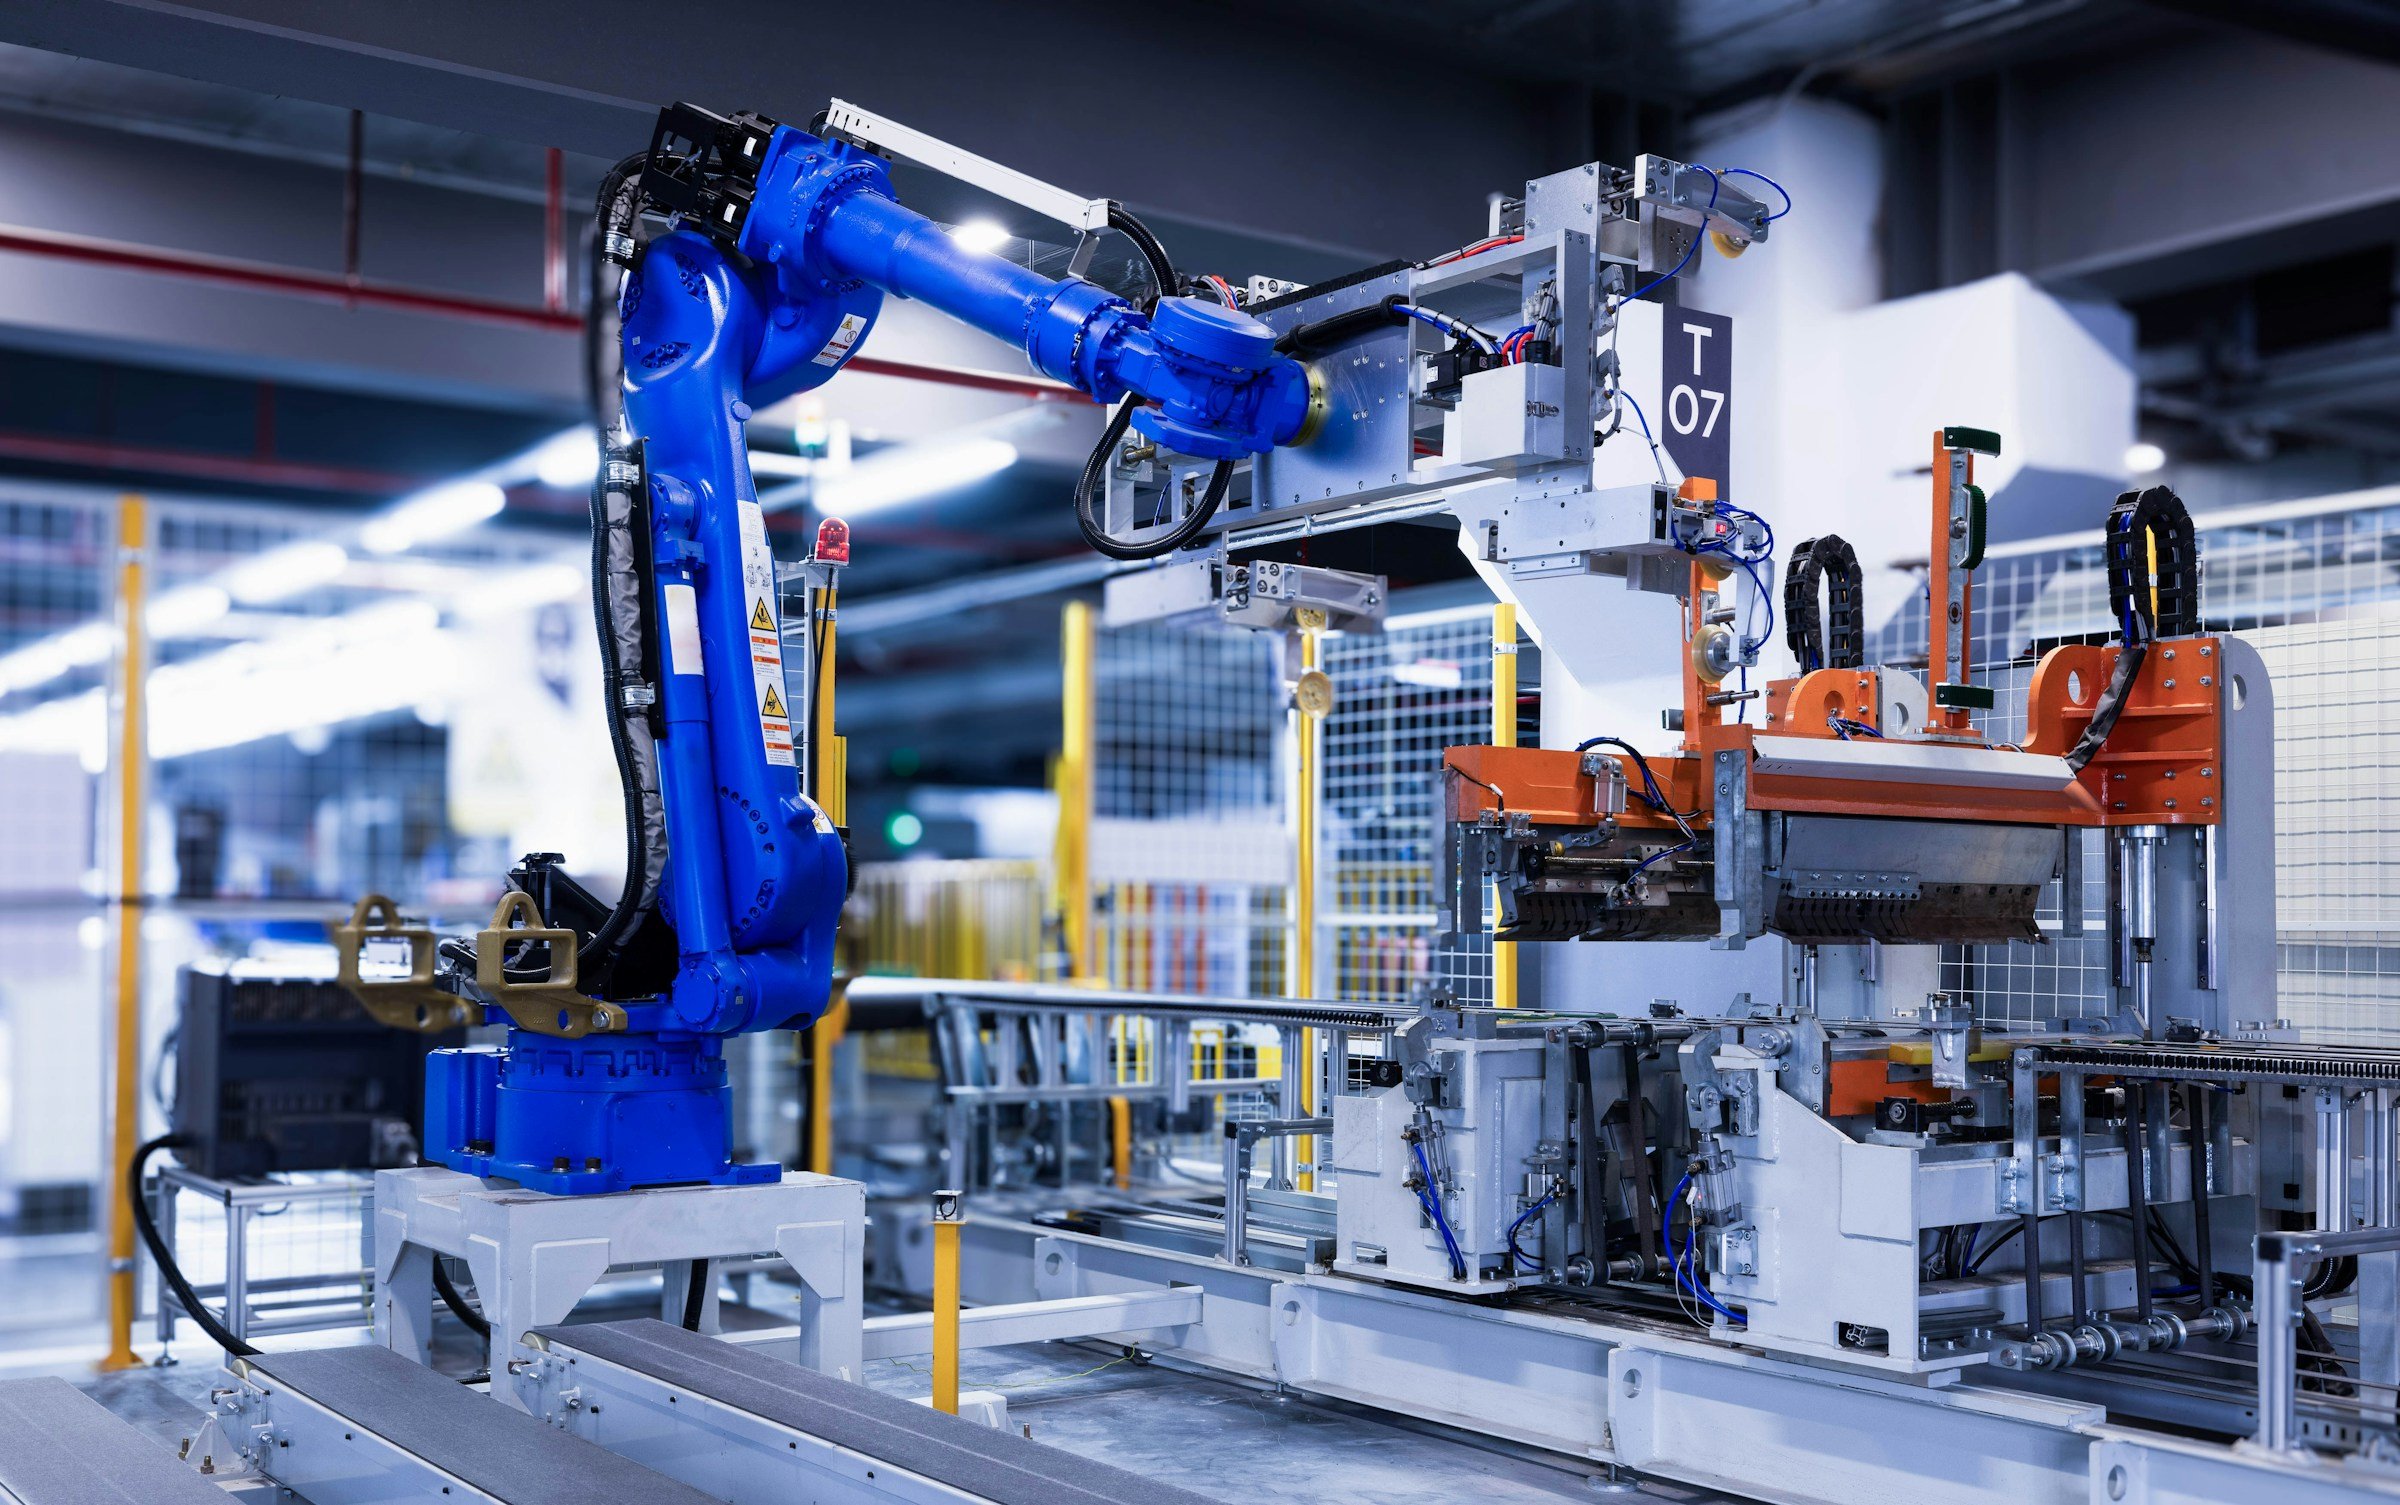
The purpose of this ARTEMIS-funded project is the development of a universal reference platform for robotic applications. Emphasis is put on cooperating, autonomous, and robust operating robots. R3-COP's approach is to create a development environment for robotic systems based on software tools, libraries, hardware platforms, and verification methodologies. Some exemplary use cases from different domains are implemented, such as underwater robots, unmanned aerial vehicles, autonomous manufactoring robots, and healthcare robots.
TU Braunschweig leads this project and contributes in the field of safety-relevant microprocessors.
Further information: www.r3-cop.eu
Contact: Jan Wagner
Funded by ARTEMIS JU, ARTEMIS-JU Call 2009, grant 100233.